
Observe without changing VR
The native dashboard discovers local cameras and keeps capture explicit. Optional MediaPipe processing adds a 2D landmark overlay and hip-relative inferred 3D coordinates.
A native WiVRn NX dashboard with optional local camera capture and MediaPipe observation, alongside a separate tracker-neutral fusion simulation.
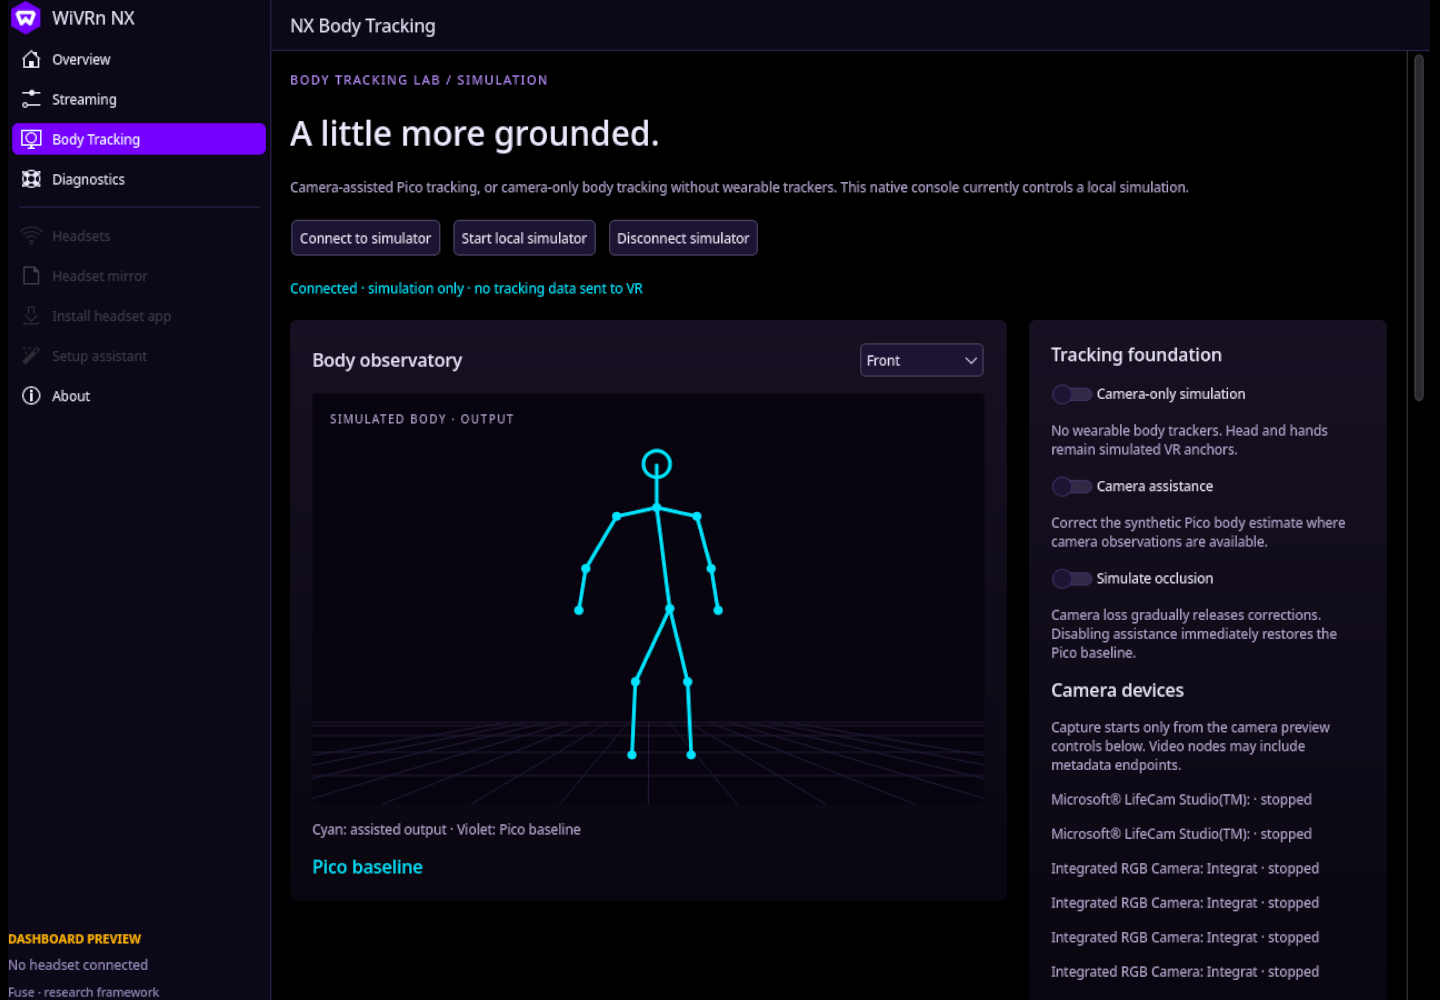
The native dashboard discovers local cameras and keeps capture explicit. Optional MediaPipe processing adds a 2D landmark overlay and hip-relative inferred 3D coordinates.
The Python service still provides assisted and camera-only simulation with per-joint confidence, fallback, and deterministic replay. It does not inject poses into WiVRn.
Camera-to-VR calibration, historical time alignment, person association, real tracker injection, and hardware evaluation remain unavailable until they are implemented and validated.
Requirements and setup vary by project. The repository documentation is the source for complete instructions.
Read the documentation ↗Build the WiVRn NX dashboard and follow its native setup guide. The Body Tracking page provides local camera discovery and explicit capture controls.
Clone nx-fuse and run python3 app.py with Python 3.10 or newer. Open the local address printed at startup; simulation needs no third-party runtime packages.
Install the optional camera dependencies, select an explicit model path, and enable a camera and estimation from the dashboard. Estimates are uncalibrated observations, not VR poses.
Python 3.10 or newer for the simulation. Native WiVRn NX dashboard for camera controls. MediaPipe and OpenCV are optional for live capture and estimation.
Research framework only. Assisted and camera-only simulations plus optional camera observations are available. Calibration, real tracker injection, and calibrated WiVRn output are not implemented; no tracking improvement has been verified.
Documentation, development, and help.